Research
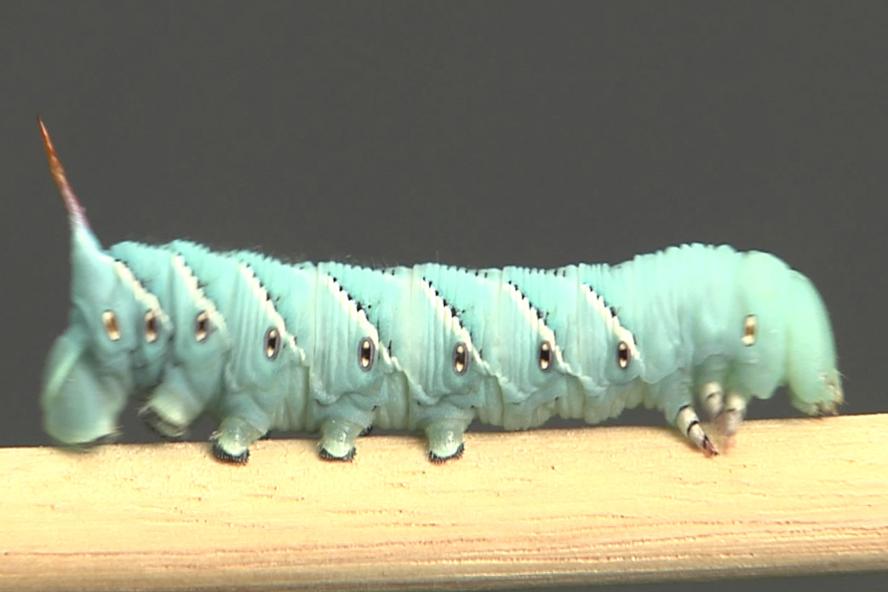
Neuromechanics of Locomotion
Animal locomotion is an intricate interplay between neural processes and biomechanics. These components have co-evolved to form "neuromechanical" control systems in which neural commands organize actions and the structures and materials of the body translate these commands into movements. In some cases structures are able to accomplish movements with relatively little or no command input, but most behaviors in natural environments require intricate neural patterning. In animals that have stiff skeletons (such as vertebrates and adult stage arthropods), these motor programs rely on the constraints imposed by joints to reduce the degrees of freedom and simplify control. In contrast to animals with skeletons, soft animals do not have the same limits on movements; they can deform in complex ways and have virtually unlimited degrees of freedom. One of our major research goals is to identify how soft animals control their movements in a computationally efficient manner using the principles of embodiment and morphological computation.
Neuromechanical control systems:
- The control mechanisms needed to move soft animals and robots are largely unknown.
- Studying the forces, movements and neural commands in soft animals can help to identify effective control strategies.
- Computational simulation techniques can also be used to "evolve" control systems for soft 3-dimensional structures.
- These experimental and simulation approaches are expected to offer new computational paradigms for engineering structures and controls for soft robots.
Neural Processing of Thermal and Mechanical Stimuli

Nociception and its Modulation: We study how animals adjust their responses to potentially harmful stimuli according to their behavioral and physiological state. Using the tobacco hornworm, Manduca sexta, we investigate how nociceptive signals are processed and modulated from peripheral sensory neurons through the central nervous system. Our work has shown that nociceptive sensitivity is highly dynamic: defensive responses can be suppressed during particular behavioral states or enhanced following previous noxious stimulation. By identifying the neural and molecular mechanisms responsible for this modulation, we aim to understand how nervous systems balance protection from injury with the need to perform other important behaviors. This comparative approach also provides insight into the evolution and general organization of nociceptive systems across animals.
Developing the MONOLITh Robot – A Soft Machine for Searching in Complex Terrain
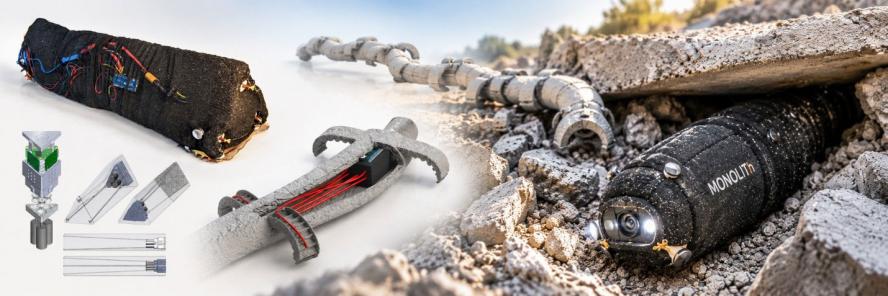
We are developing the next generation of MONOLITh, our bioinspired, untethered soft robot, as a mobile platform for searching and navigating complex, unstructured terrain. The original MONOLITh uses a highly compressible foam body, tendon-based actuation, a functional fabric skin, and onboard power and control, allowing it to remain approximately 95% soft by volume while carrying its own weight and recovering from substantial deformation. Our current goal is to build on these principles to create a more capable machine that can crawl through confined spaces, negotiate irregular surfaces and obstacles, and tolerate impacts and deformation that would challenge conventional rigid robots. By combining soft materials with biologically inspired locomotion and sensing, we aim to understand how mechanical compliance and body design can themselves contribute to mobility and control, while developing practical robots for exploration and search in environments that are difficult to predict in advance.
Tissue Engineering of Novel Devices
One of our long-term goals is to "grow" robotic devices using a combination of biosynthetic materials, cellular modulation, and tissue engineering. In collaboration with Professors Kaplan and Levin we are exploring both invertebrate and vertebrate cell culture and regeneration systems to structure muscles and supporting tissues on scaffolds of biomaterials. These scaffolds could be degradable or allowed to remain as part of an operational biorobot. Such biological devices will be controlled using the simulation tools developed for synthetic soft robots and will exploit recent advances in soft material electronics.
For these cell-based systems, we are generating bundles of contractile skeletal muscle tissue using insect muscle cells. These constructs will be engineered to contract in a controlled, coordinated fashion for eventual use as motors in soft robots. Insect cells offer novel features, such as high force, low oxygen demand, and low sterility requirements that are particularly advantageous.
Biosynthetic robots:
- Growing robotic devices: A completely new approach to building machines
- The goal is to harness the intrinsic structure-building capability of cells.
- The approach is to make biopolymer scaffolds with signaling molecules that direct cells into the desired shapes and functions.
- Hybrid devices grown on conducting substrates can be connected to implanted microchips for autonomous or remote teleoperation.
- These devices will be cheap, mostly biodegradable and biocompatible for use in medical and environmental applications.
